Skip to content
Robots For Roboticists Robots For Roboticists

Robotics Blog for the Professional Roboticist

  • Home
  • About
  • Robotics Dictionary
  • Vendor Directory
  • Events
  • Misc

elevation

  • Home
  • elevation
coordinate frames
Posted inSoftware & Algorithms Systems & Sensors

Coordinate Systems (Where in the world is your robot?)

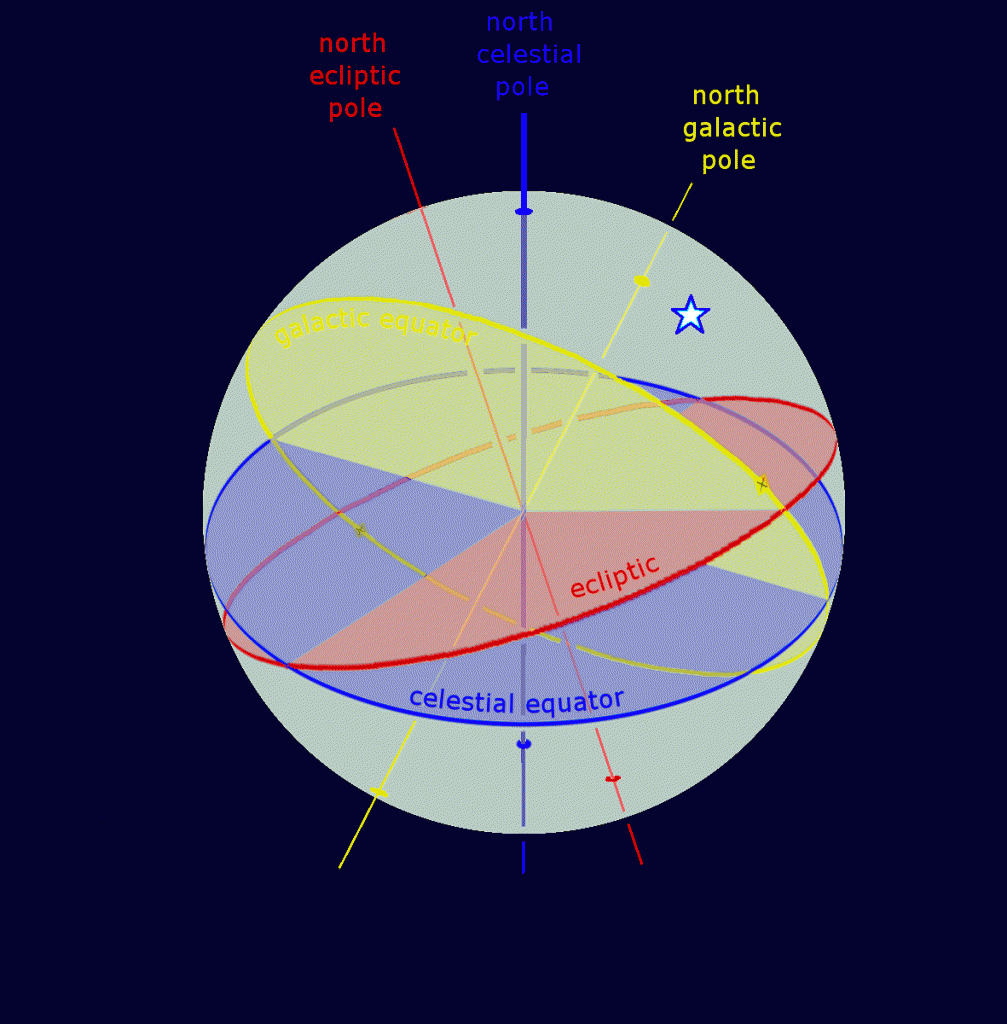
Hi all There are many ways of expressing your position in the world. We can use those same methods to represent where in the world your robot is. At the highest level there are two types of coordinate frames; global and local. In the global frame the robots position is specified based on a pre-established method that can uniquely identify…

Robotics Blog for the Professional Roboticist


  • Computing & Networking
  • Electrical & Electronics
  • Mechanical
  • Misc
  • Research
  • Robots
  • Software & Algorithms
  • Systems & Sensors
  • Testing
  • Uncategorized
Top Posts & Pages
  • Upcoming Robotics Conferences & Events List
  • Mechanical & Wheels - Hands On Ground Robot Design
  • Cruising on a Cruise Ship on Shabbat (or Shabbos)
  • E-stop and M-stops
  • Wheel & Grouser Design
  • Drive Kinematics: Skid Steer & Mecanum (ROS Twist included)
  • Listing Category
  • Antenna Separation: How Close Can You Go?
Upcoming events:
  • Mon
    17
    May
    2027

    HRI 2027

  • Mon
    24
    May
    2027

    ICRA 2027

  • Mon
    15
    May
    2028

    ICRA 2028

My Tweets
Copyright 2026 — Robots For Roboticists. All rights reserved. Bloghash WordPress Theme
Scroll to Top